Luca Scimeca

AI Research Scientist & Founder

News & Posts

Press coverage, interviews, posts, and more.

In the media

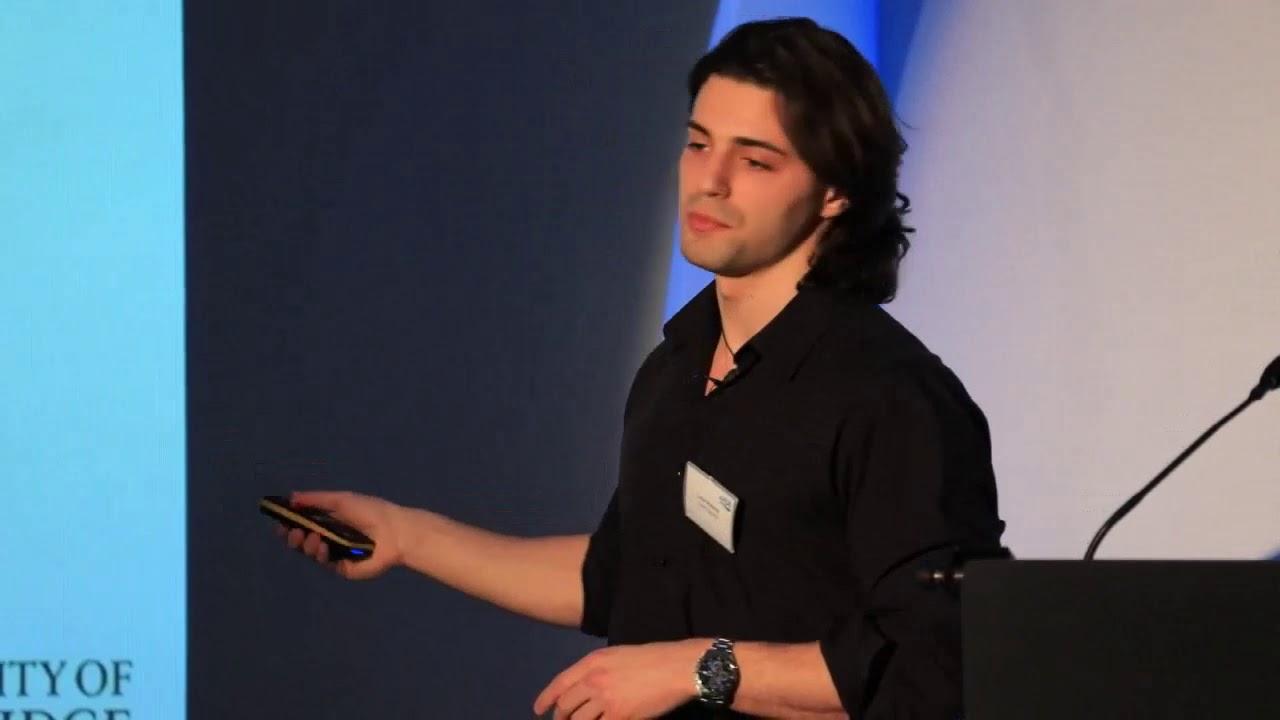
Talk SmartHort 2019

Agricultural robotics at the University of Cambridge

At SmartHort 2019, a UK conference on new technology for horticulture, Luca Scimeca presents the agricultural robotics work he led at the University of Cambridge. He shows a lettuce-harvesting robot that cuts reliably, though still more slowly than human pickers, explains why soft, hard-to-model crops are so difficult for robots, and discusses the long road from research prototype to a machine growers can use.

Press University of Cambridge

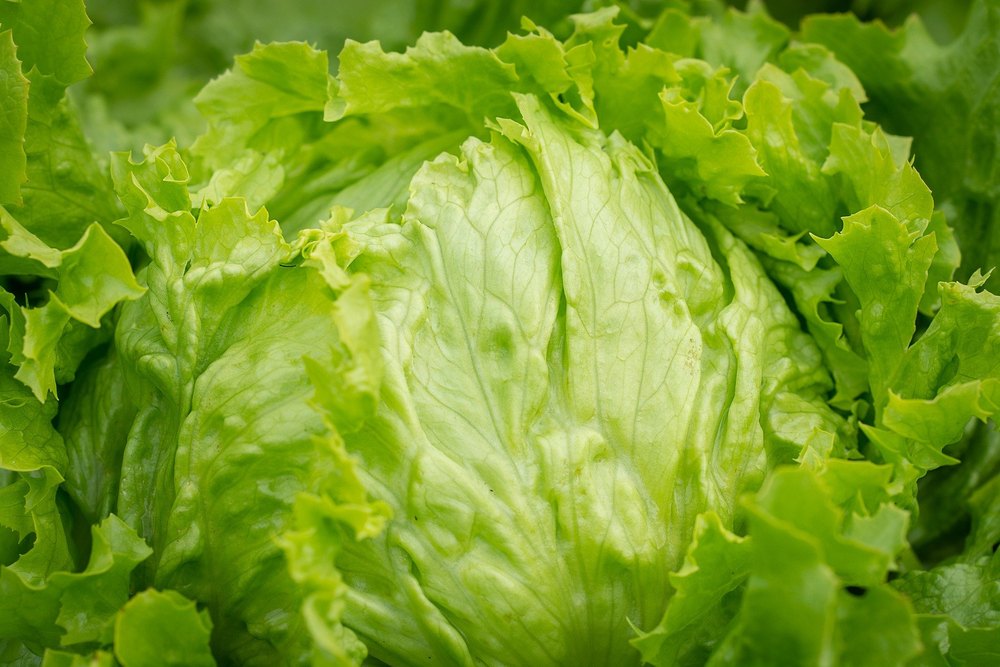
A first-of-its-kind robotic lettuce-peeling system

Removing the outer leaves from an iceberg lettuce is still done by hand. A team at Cambridge's Machine Intelligence Laboratory paired a machine vision pipeline with a 3D-printed suction nozzle that tears each leaf away without bruising the head. It fully removed a leaf in half of its attempts, taking about 27 seconds on average. Published in IEEE Robotics and Automation Letters.

Posts

20 Jun 2024 · NeurIPS 2024 Unlocking the Power of Diffusion Models: A Dive into Relative Trajectory Balance

Diffusion models are excellent at generating data. Getting them to also respect a constraint means sampling from an intractable posterior — Relative Trajectory…

Read
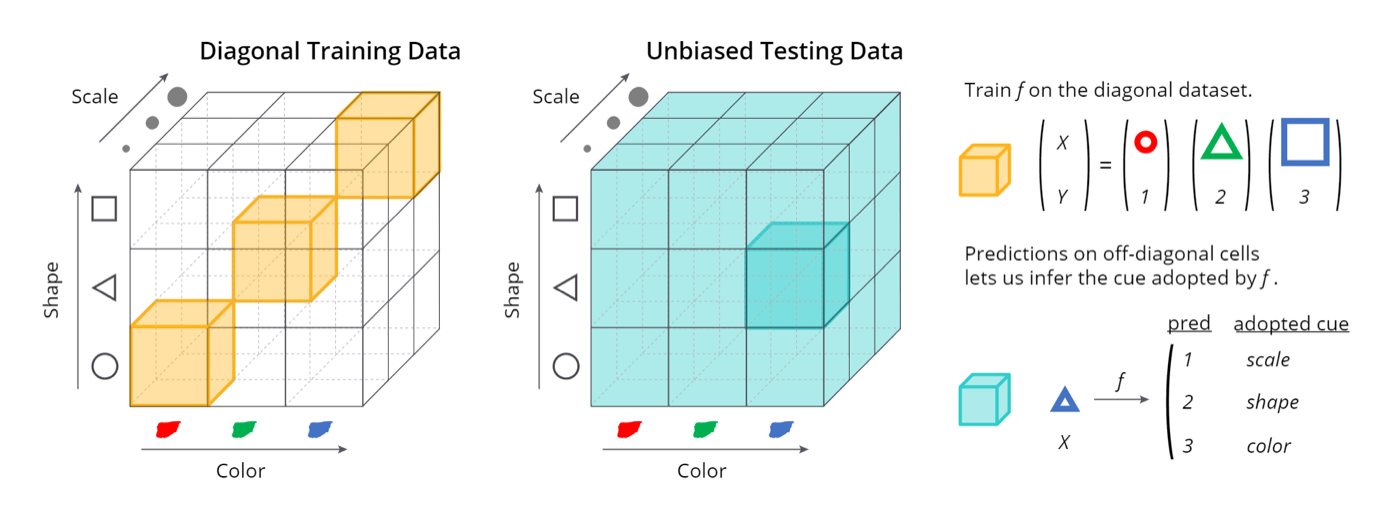
31 Jul 2023 · ICLR 2022 Shortcut Learning in Deep Neural Networks: Which Cues Will Your Model Choose to Learn?

Deep networks lean on whatever feature is easiest to fit — recognizing ducks by the lake behind them. We build a test that exposes which cues a model prefers…

Read
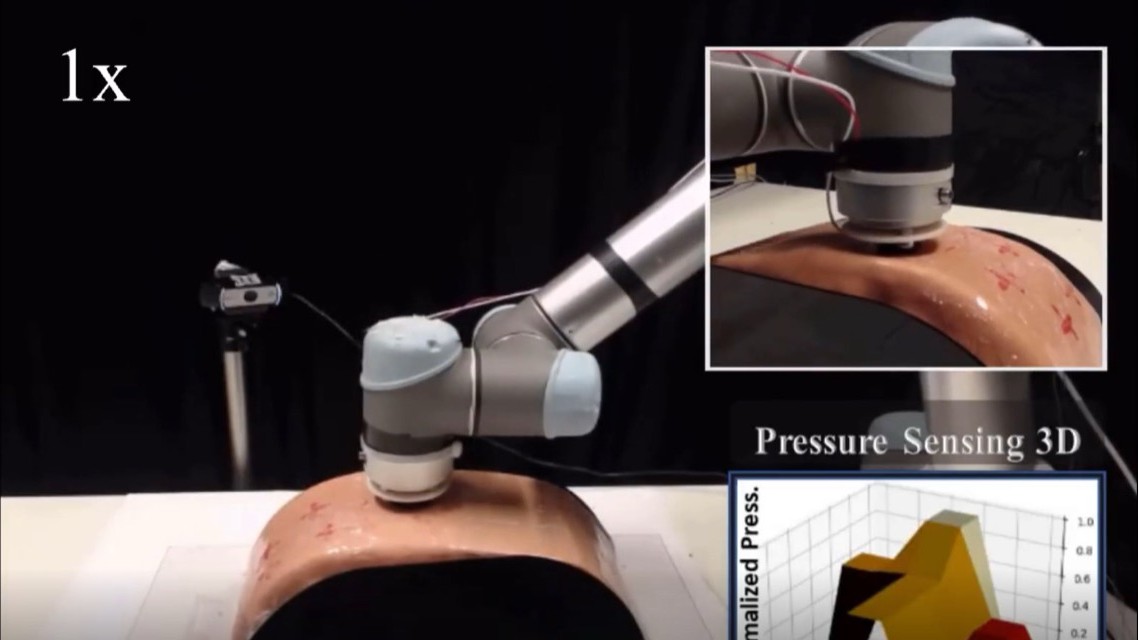
05 Sep 2021 · University of Cambridge Introducing RoboPatient — A Soft Robotics Approach to Training Doctors

Cambridge researchers are designing the healthcare robotics of the future by investigating a robot-assisted approach to training doctors in medical examinations.

Read
14 Aug 2020 · PLOS ONE Gaussian Process Inference Modelling of Dynamic Robot Control for Expressive Piano Playing

A robot that can autonomously learn to play piano by mimicking the dynamics of different human playing styles.

Read
29 Jul 2020 · Autonomous Robots Structuring of Tactile Sensory Information for Category Formation in Robotics Palpation

Robotics and medicine — applying machine learning and tactile sensing to the autonomous detection of abnormal lumps in soft bodies.

Read
15 May 2020 · IEEE RoboSoft 2020 Efficient Bayesian Exploration for Soft Morphology-Action Co-optimization

A mathematical framework for the active exploration of robot control and morphology, to aid in tactile discrimination tasks.

Read

Leaving the site

Publications live on Google Scholar